
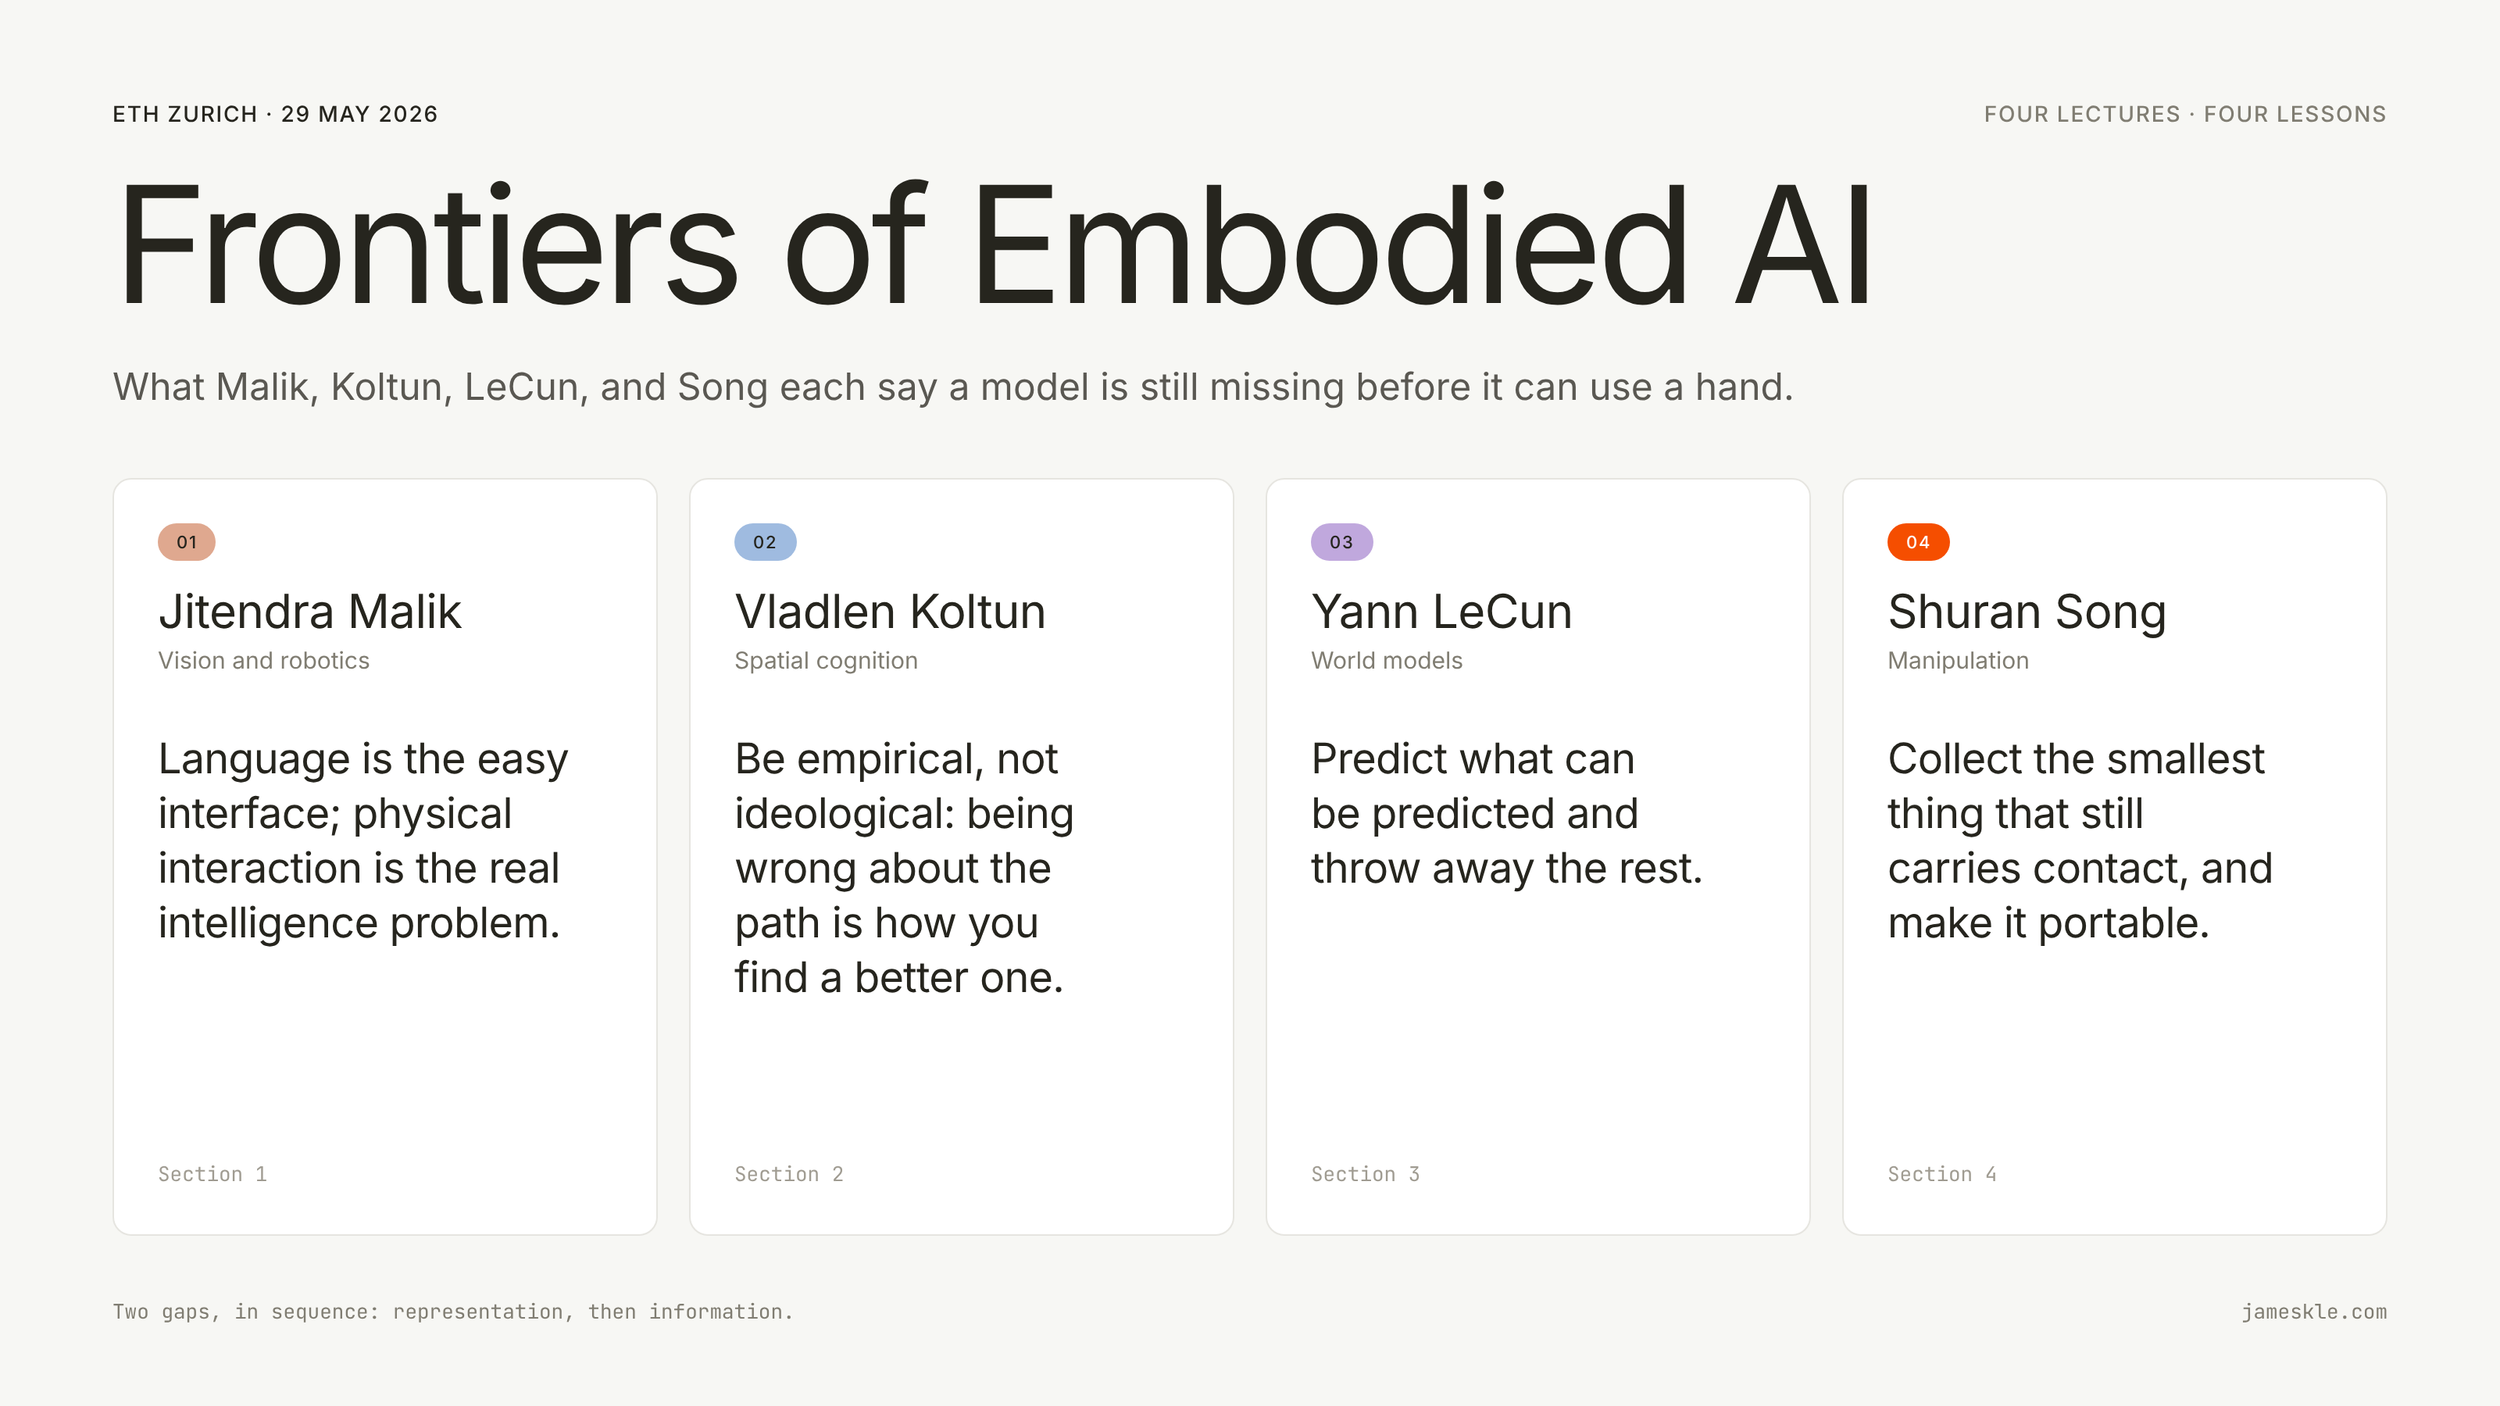
A language model can write the omelet recipe. Cracking the egg is where robots stall. That was Jitendra Malik's opening example at ETH Zurich on 29 May 2026, the first of four lectures under the title Frontiers of Embodied AI. I watched all four, about 3 hours 17 minutes in total, and they answer four different questions: what a robot's body needs (Malik), how well frontier models understand space (Vladlen Koltun), how a system learns a world model (Yann LeCun), and how to collect manipulation data that carries contact (Shuran Song). This post walks through them in order, then says which gap I think is the real one: a model that can't find the bathtub is missing structure, but a policy that can't feel the egg is missing a signal.